Obstacle Avoidance Robot
An autonomous wheeled robot that navigates unfamiliar environments using ultrasonic distance ranging and servo-swept path decisions.
Certificate of Participation — Obstacle Avoiding Car Workshop
🏆 Hands-on Workshop Certification
Issued by: Shikshadeep B.S.S., Biratnagar-9, Morang, Nepal
“Awarded by Chief Minister Hon. Hikmat Kumar Karki and Shikshadeep B.S.S. leadership for active participation and project execution in the Obstacle Avoiding Car workshop.”
Verified Achievement
Official credential validating competitive performance, technical presentation, and engineering execution. Click the preview to inspect the original high-resolution document.
View Full ResolutionAbout the Project
An autonomous mobile robot designed to explore indoor environments without human intervention. Mounted with an ultrasonic sensor on a sweeping micro-servo, the robot scans its surroundings when detecting an obstacle ahead, evaluates clearance paths to the left and right, and executes autonomous avoidance turns.
Key Engineering Features
Active 180-degree servo panning to measure situational clearances before turning
Autonomous path-decision algorithm picking the widest open avenue
Collision avoidance thresholding with reverse and pivot escape sequences
High-grip rubber wheels and dual motor differential drive
Hardware & Microcontrollers
Key physical modules, sensors, and IC components integrated:
- Arduino Uno
- HC-SR04 Ultrasonic Sensor
- SG90 Micro Servo
- L298N Dual H-Bridge
- Gear Motors & Swivel Caster
Software & Protocols
Firmware libraries, communication protocols, and control stacks:
- Arduino C++
- Servo Sweep & Ranging Logic
- Differential Steering Routines
Project Gallery & Prototype Views
Snapshots, schematics, and functional bench tests for Obstacle Avoidance Robot.
Servo & Ultrasonic Sensor Head
Front-mounted scanning assembly that rotates dynamically to detect path clearance.
Navigation Test Run
Autonomous obstacle avoidance and path planning through indoor labyrinth tests.
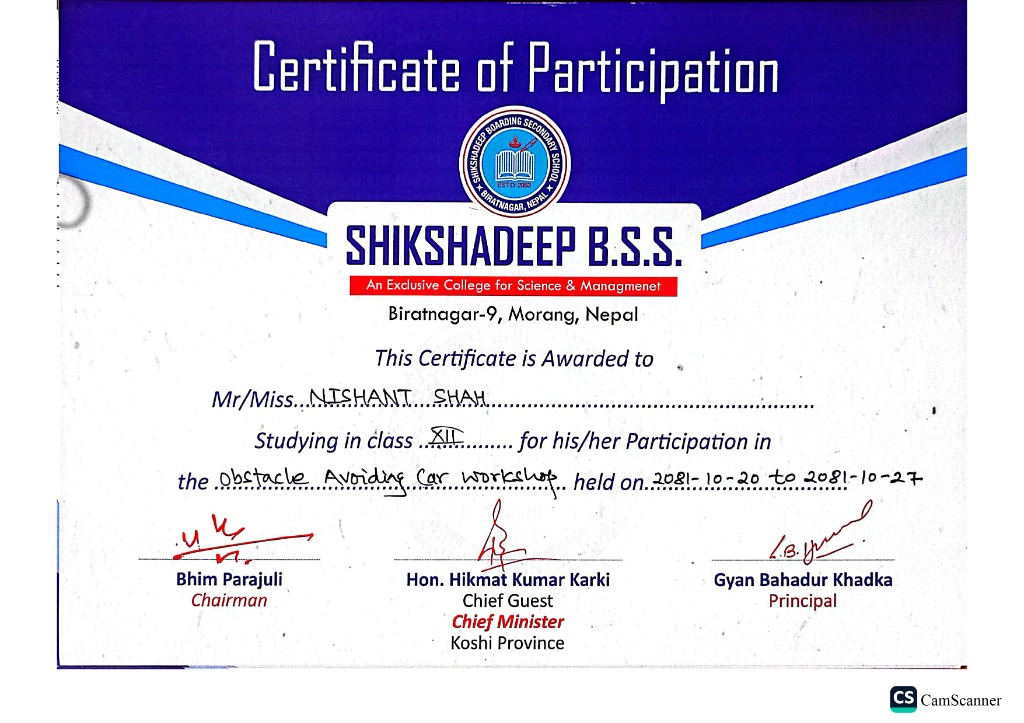
Workshop Certificate of Participation
Official certificate awarded at Shikshadeep B.S.S. by Hon. Chief Minister Hikmat Kumar Karki.