Robo Soccer Bot
A high-speed competition robot engineered for robo-soccer tournaments, tuned for agility, swift torque response, and competitive ball control.
Certificate of Participation — Robo Soccer
🏆 Robo Soccer Tournament Semi-Finalist
Issued by: Robotics Association of Nepal - EAST (Koshi Yantra 3.0)
“Successfully participated in Robo Soccer at Koshi Yantra 3.0, Fujisan Sagarmatha Boarding School, Itahari-19, Bhawanipur, advancing through the brackets to the tournament semi-finals.”
Verified Achievement
Official credential validating competitive performance, technical presentation, and engineering execution. Click the preview to inspect the original high-resolution document.
View Full ResolutionAbout the Project
Engineered specifically for competitive robo-soccer arenas where agility, low ground clearance, and instant acceleration determine victory. Built using dual high-RPM planetary metal gear motors, heavy-duty motor drivers, custom chassis reinforcement, and low-latency wireless radio control. Advanced through tournament preliminary rounds and reached the semi-finals in competitive play.
Key Engineering Features
Custom low-profile chassis with center-of-gravity optimization for anti-topple stability
High-current motor driver circuit capable of delivering peak bursts without overheating
Low-latency 2.4GHz radio frequency transceiver control with dual joysticks
Durable ball-dribbling and guide scoop designed to maintain control under contact
Hardware & Microcontrollers
Key physical modules, sensors, and IC components integrated:
- High-RPM Metal Gear DC Motors
- High-Amp Dual Motor Driver
- 2.4GHz RF Transceiver
- LiPo 3S Battery Pack
- Custom Reinforced Acrylic/Aluminum Frame
Software & Protocols
Firmware libraries, communication protocols, and control stacks:
- Embedded C++
- PWM Motor Curve Tuning
- Fail-safe Radio Signal Handler
Project Gallery & Prototype Views
Snapshots, schematics, and functional bench tests for Robo Soccer Bot.
Robo Soccer Bot Arena Stance
Low-clearance combat-ready chassis with optimized front ball-scoop geometry.
Drivetrain & High-Torque Motors
Dual geared motor configuration configured for high-speed counter-rotations and sprint bursts.
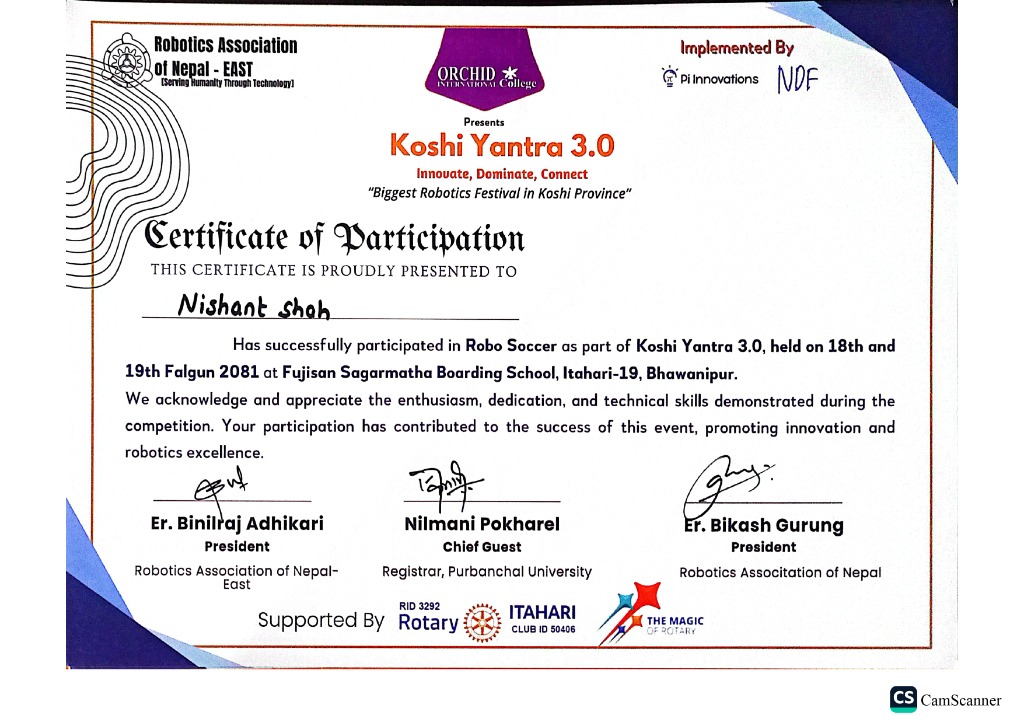
Tournament Semi-Finalist Certificate
Official participation certificate and semi-finalist recognition from Robotics Association of Nepal - EAST (Koshi Yantra 3.0).